Relocating to Tampa Bay, FL

Mark Matheson

Robotics & Automation Field Service Engineer

I keep complex automation systems running and optimized. 15+ years on the front line between the people operating equipment and the engineers who designed it.

Mark Matheson
15+years in robotics & automation
95%equipment availability sustained
60sstation cycle times held
32accounts across a 3-state territory

Experience

Robot Specialist

BMW Manufacturing · Greer, SC

Feb 2023 – Present

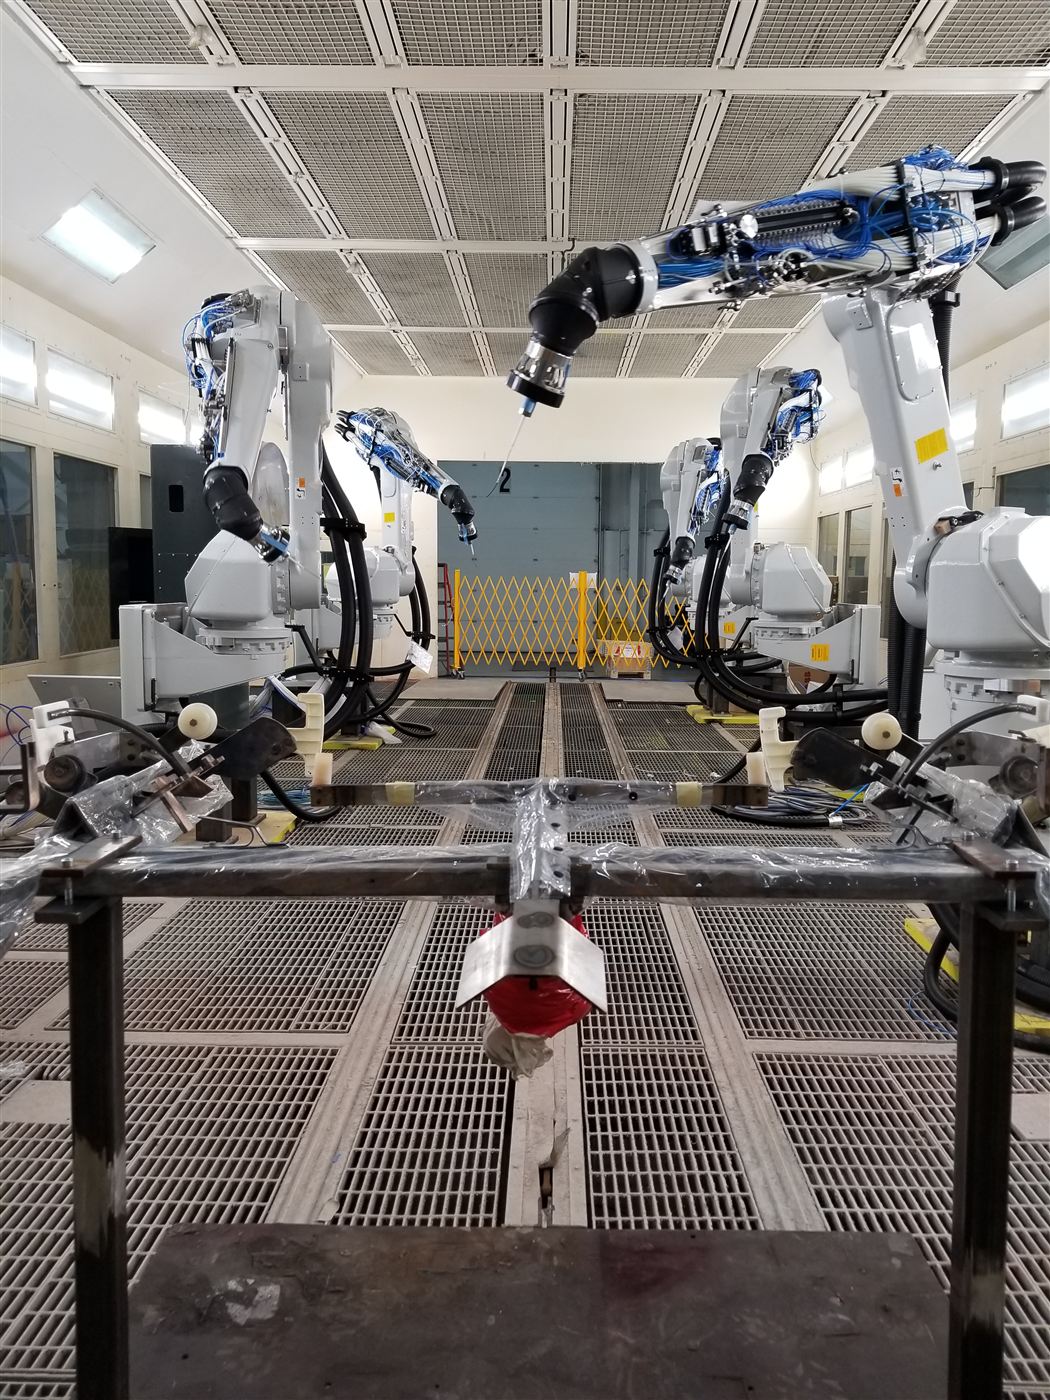
  • Lead technical development of paint shop automation across ABB, Dürr, and Fanuc robots: new model programming, design changes, and continuous improvement.
  • First responder for planned and unplanned downtime, helping sustain 95% equipment availability.
  • Key contributor to holding 60-second station cycle times through path optimization and process re-sequencing (see how).
  • Offline programming in RobotStudio, Process Simulate, and Dürr 3D Onsite. Design and 3D print custom robot tooling.
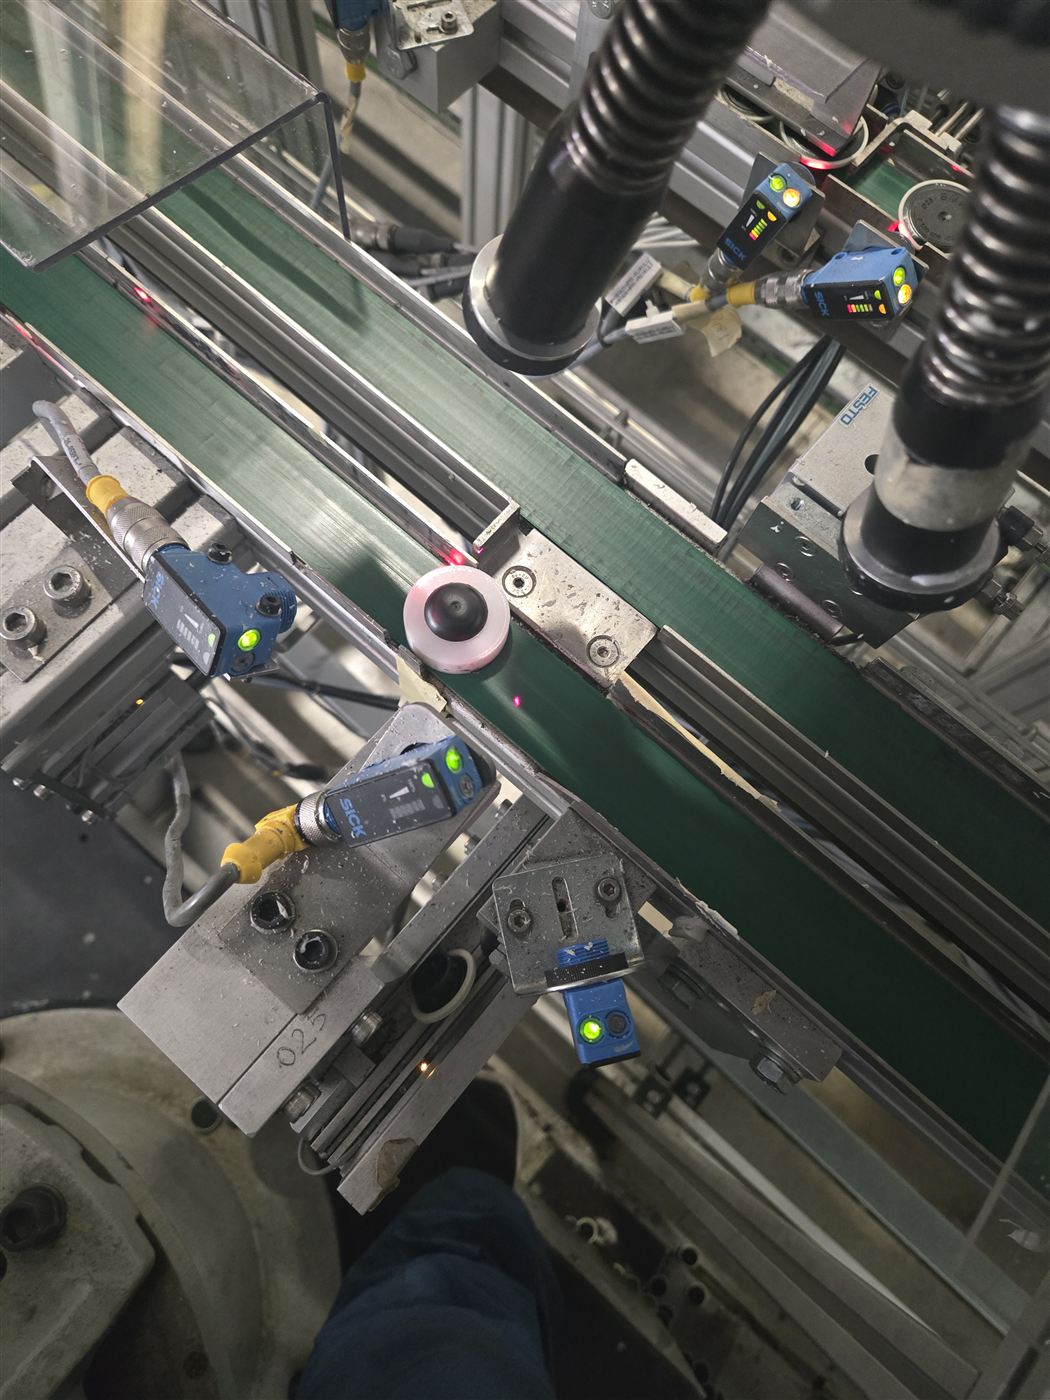
Conveyor station with photoelectric sensors and vision hardware
Sensor and vision station work
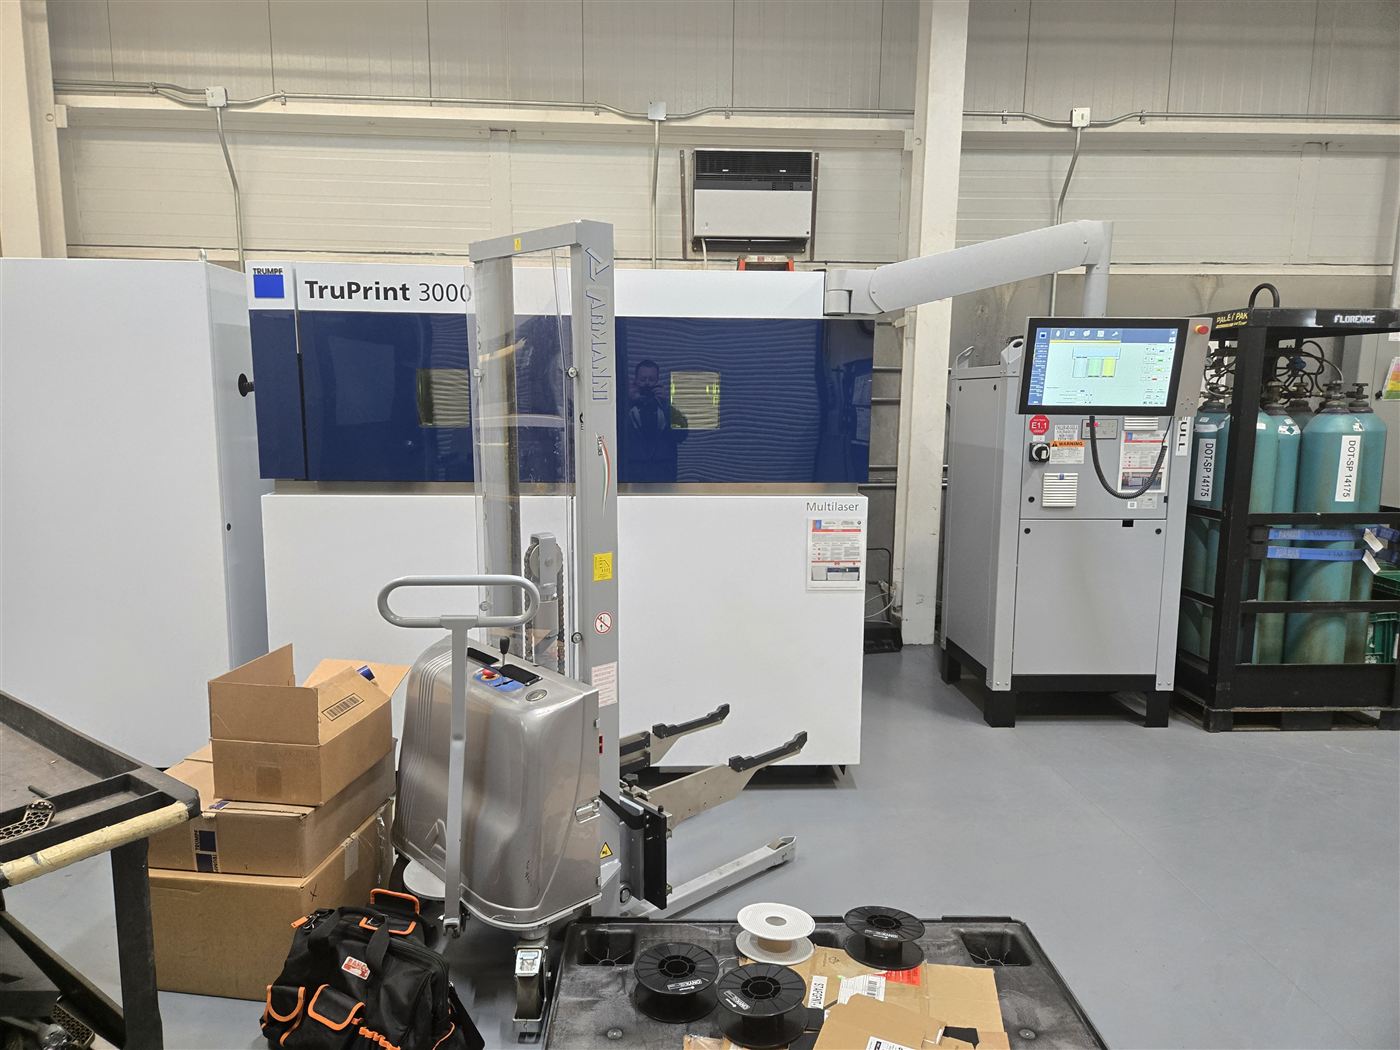
TruPrint 3000 metal additive manufacturing machine
Additive manufacturing equipment
Pressure-testing PVC with an Omni flat tip

Field Service Engineer

Medtronic

Jan 2021 – Feb 2023

  • Owned a 32-account territory across South Carolina, western North Carolina, and east Tennessee, working independently.
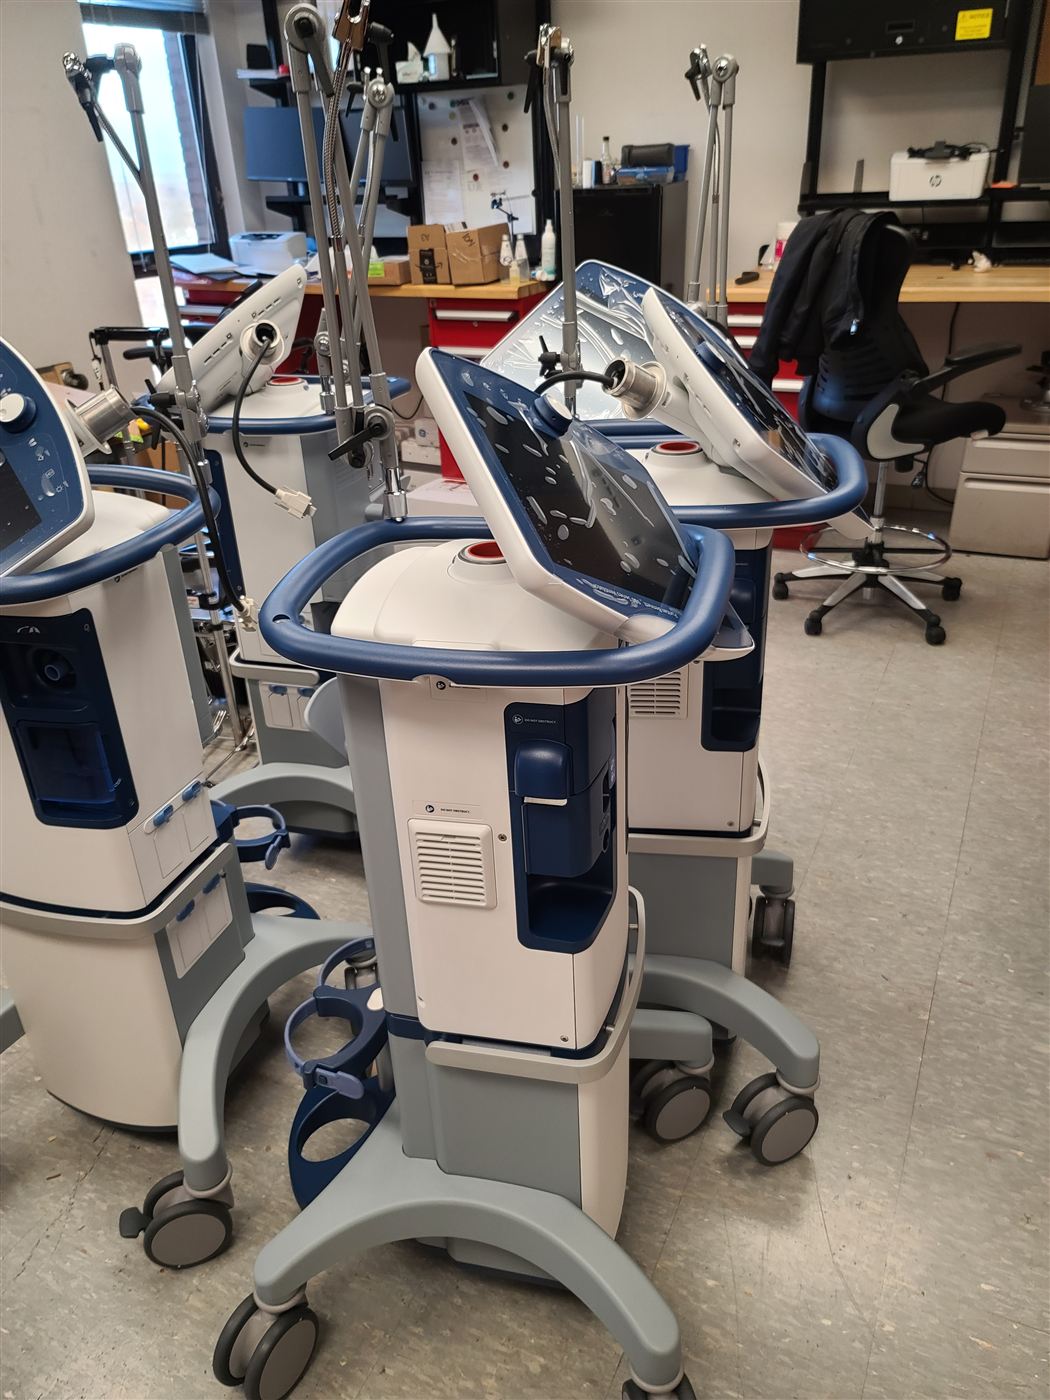
  • Installed, repaired, and upgraded Puritan Bennett 980/840 ventilators at hospital sites, where uptime is a patient-safety issue.
  • Executed engineering field changes and trained customer biomedical staff onsite.
Puritan Bennett 980 ventilators in a service shop
PB980 ventilators in for service
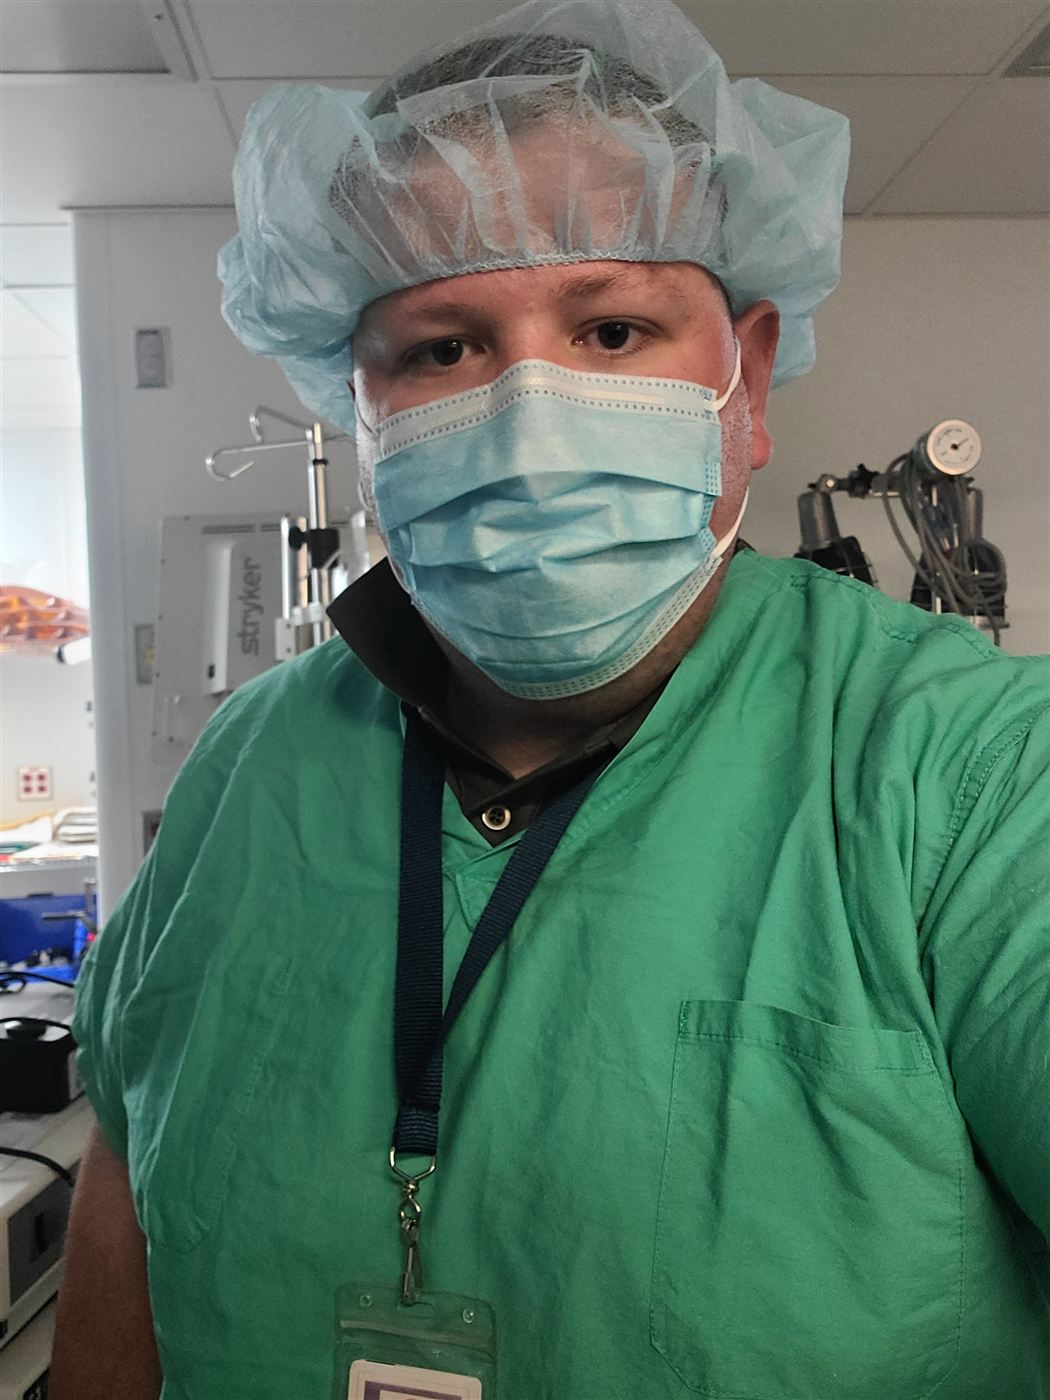
Mark in scrubs in a hospital operating room
On site in the OR

Field Service Engineer

ABB

Nov 2017 – Dec 2020

  • Commissioned new sealer and paint robot cells at customer plants, from install through production handoff.
  • Programmed Flex Vision and pick-and-place applications. IRC5/IRC5P controllers and IPS paint systems.
  • Programmed a 16-robot masking plug cell for BMW on IRB robots and vision learned on the job: on-time launch, 60-second cycle, 95% plug success (see the project). Employee of the Month.
  • Delivered cycle time improvements and onsite troubleshooting and repair.
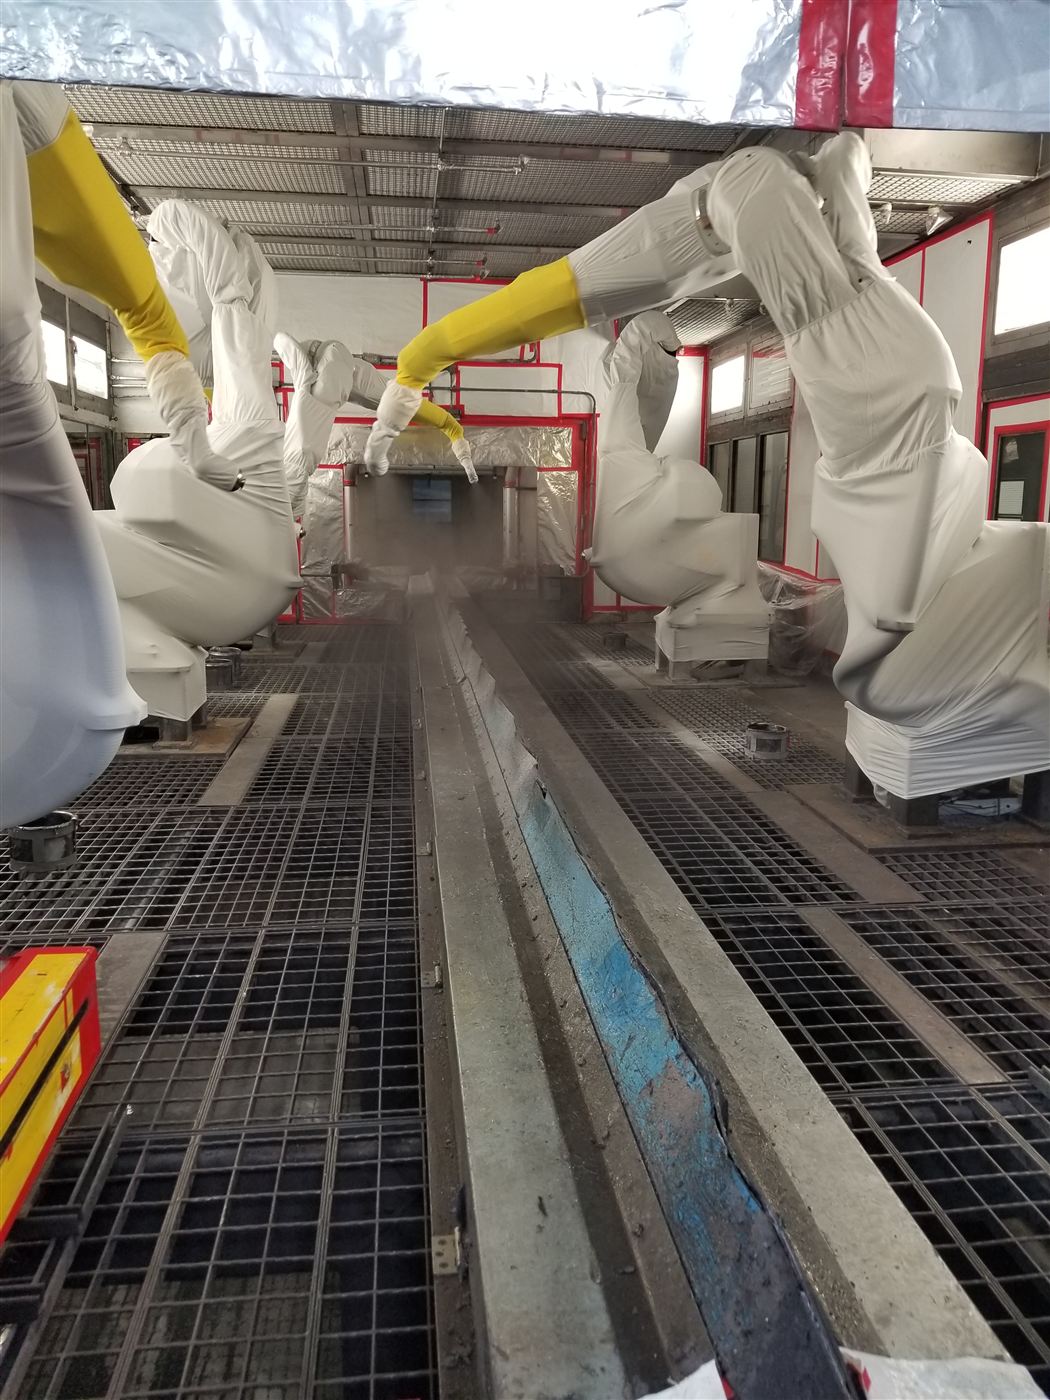
Paint booth with covered robots during a spray trial
Paint booth trial run
ABB facility entrance
ABB

Robot Programmer

BMW Manufacturing · Greer, SC

Aug 2011 – Nov 2017

  • Created paint programs for new models and ran paint trial bodies.
  • Troubleshot and corrected paint defects. Set up color tables for Bell RB1000 applicators.
  • Member of the commissioning team for the IPP and Wax lines.
  • Came up from the paint line floor: repair, E-coat sand, inspection & polish, robot operator.

Diesel Technician

Morgan Corporation

Sep 2010 – Jul 2011

Where it started: overhauls and offsite repairs, keeping equipment downtime to a minimum.

How I cut cycle time

Most cycle time isn't lost in the motion. It's lost in waiting. A robot finishes one task, then the system starts the next. When a step doesn't actually depend on the one before it, it doesn't have to wait.

One example: the vision system doesn't need the robot sitting at its ready position to measure the car. So instead of tool change → move to ready → fire vision → calculate corrections, vision fires and the corrections are calculated while the robot is still finishing its tool change. The robot arrives with its offsets already waiting.

Project spotlight: BMW masking plug cell

In 2018 ABB moved me, a paint specialist, onto a 16-robot cell that installs masking plugs into BMW car bodies, on robot and vision platforms I had never programmed. It launched on schedule.

16robots in the cell
60scycle time
95%plug success rate
On timehit the launch date

The problem

Plugs only seat within tight tolerances, and the car body could shift slightly during the install. A straight-line insert would miss or seat badly.

What I did

Learned IRB robots and vision on the job from ABB documentation, on-site trials, and BMW's own people. Programmed paired robots on opposite sides of the body to push at the same instant, so the opposing forces held the body still. Then I studied how line workers installed plugs by hand and built their technique into the robot paths with RelTool offsets.

The result

Launched on the date, at a 60-second cycle and 95% plug success. The remaining misses traced back to plugs jamming on the feed conveyor, not to insertion. Named ABB Field Service Employee of the Month.

“Mark has performed above expectations and has excelled throughout. Mark has been instrumental in the success of the Masking Plug project.”

Director of Field Services & Technical Support, ABB. Employee of the Month award, June 2018

What I'd do sooner: start on the plug deck with the line workers on day one. Their hand technique was the key to the robot programs.

Skills & certifications

Troubleshooting & root cause

Robotics, electrical, electromechanical, and fluid/pneumatic systems, under production pressure.

Launch & commissioning

New robot cells (sealer, paint, pick & place), BMW IPP and Wax lines, customer-site installs.

Continuous improvement

Cycle time reduction, downtime recovery, quality defect elimination, issue tracking to closure.

Software & tools

ABB RobotStudio / RAPID, Siemens Process Simulate, Dürr 3D Onsite, CAD and 3D printing.

Documentation & training

Technical procedures, engineering field changes, onsite customer training.

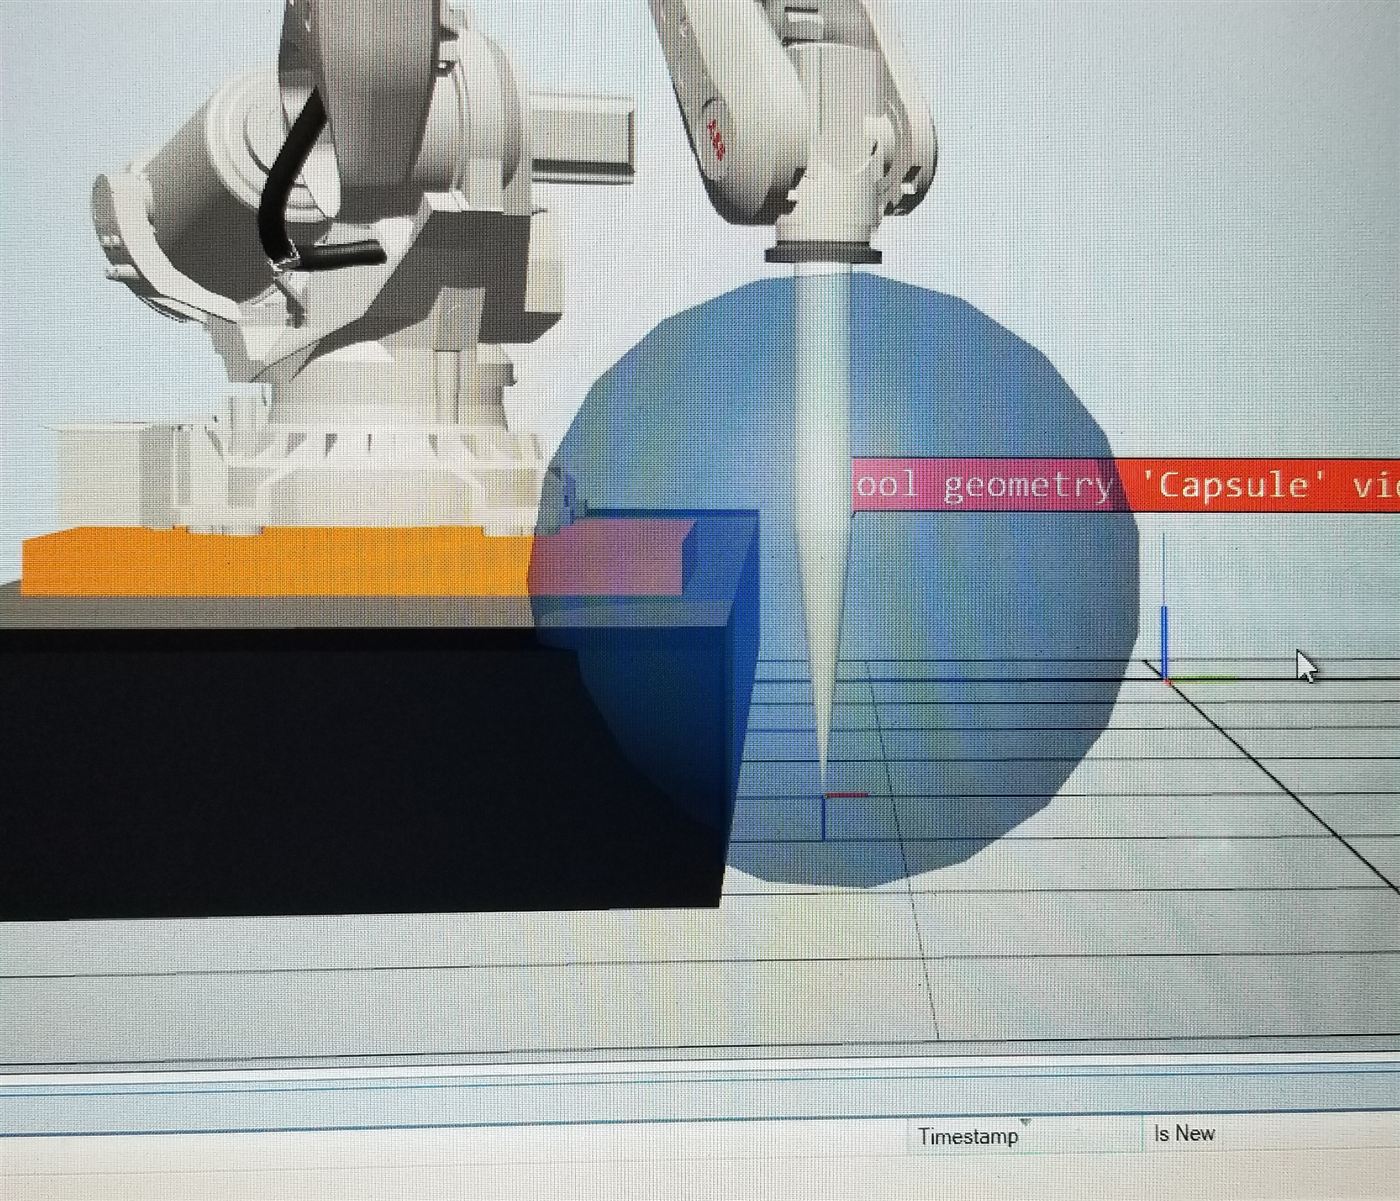
ABB RobotStudio simulation showing a robot and tool geometry
Offline programming in ABB RobotStudio

Certifications & training

  • ABB RobotStudio
  • ABB IRC5P Electrical
  • ABB IPS
  • ABB SafeMove 2
  • ABB Flex Vision
  • Fanuc Dispense Tool & Programming
  • Puritan Bennett 980 / 840 Service
  • CCNA (in progress)
  • Associate Degree, Management & Diesel Technology (WyoTech)
Mark at Fanuc training holding a stack of course manuals
Fanuc training. Always learning.

Off the clock: the homelab

Modern automation lives on the network, so I built one. Everything outside my robot work is self-taught, and this is where I practice it. Configs and design notes on GitHub →

Virtualization

Three-node Proxmox cluster with high availability and replication. The nodes are named after my kids.

Networking

UniFi network segmented with VLANs, WireGuard VPN, and Cloudflare Tunnel for secure remote access with no open ports.

Storage & backup

Synology NAS with immutable snapshots and an offline backup drive, protecting against ransomware.

Automation

Home Assistant runs the house: lighting, presence, energy, and dashboards.

Self-hosted AI

A local LLM operations assistant on a Mac mini that monitors the lab, answers questions, and escalates problems.

Monitoring

Uptime monitoring and alerting across every service, the same way I'd want a production line watched.

Let's talk

Open to field service, automation, and reliability engineering roles in the Tampa Bay area.